

DD-GBP reaches 92.5% completion in robot-arm tests
The arXiv preprint reports resilience under 90% packet loss, but the robotics results remain early and not peer reviewed.
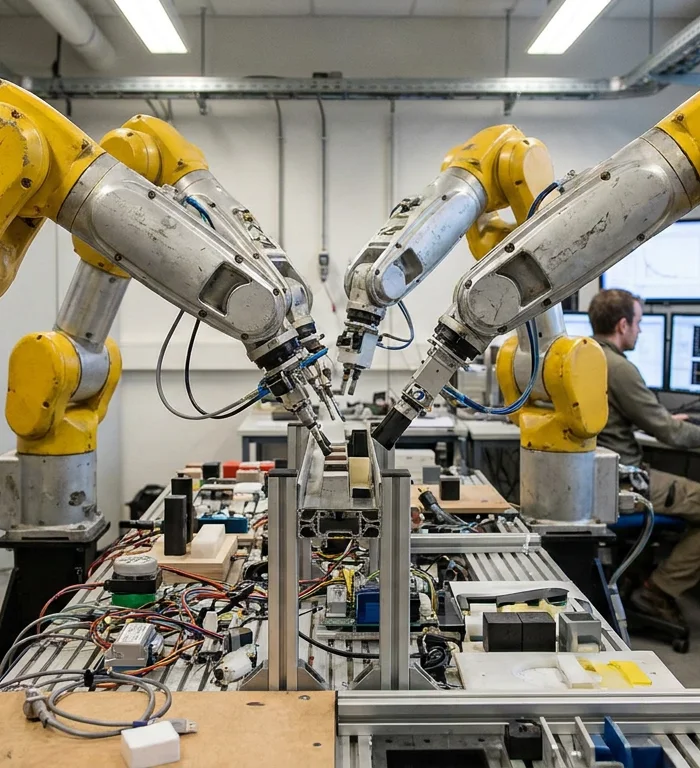
DD-GBP achieved 92.5% completion of all targets without collisions in 50 four-arm scenes with moving obstacles, according to an arXiv preprint submitted Oct. 14 by Zhao Jin and five co-authors.
The result matters because DD-GBP also retained 86.0% success under 90% packet loss, while the authors said it posted the highest success rate among six representative baselines in the same benchmark.
The paper describes DD-GBP, short for distributed dynamic Gaussian belief propagation, as a planning method for coordinating multiple robot arms during long tasks in changing environments. Gaussian belief propagation is a probabilistic message-passing technique used to infer a solution across connected variables.
The authors said the method “directly plans joint-space trajectories through parallel local inference.” Joint-space trajectories describe how each robot joint should move over time, rather than only the end position of a robot arm.
Each robot arm keeps a local tree-structured factor graph, a model that breaks a planning problem into connected constraints, and exchanges asynchronous messages with other arms over active links, according to the preprint. The authors said dynamic subnet reconstruction and event-triggered updates lower communication and inference costs while the system responds to moving obstacles.
The paper also reports tests beyond the 50 four-arm scenes. In obstacle-free experiments on one workstation, DD-GBP kept 99.87% success with 30 coexisting arms and produced a 15.80 millisecond mean warm solve, which the authors said exceeded 60 Hz and outperformed the compared methods in scalability.
The authors said DD-GBP uses a unified Gaussian-process parameterization, meaning a statistical model for smooth trajectories, to connect adaptive planning horizons, interpolation-time factors and continuous execution. The paper also presents theoretical analyses covering local inference accuracy, anytime early stopping, triggered-replanning consistency and Gaussian-process-consistent execution.
Execution results showed lower extreme velocity and acceleration peaks than Syn-GBP, according to the authors. The abstract does not provide the exact peak reductions, the full list of compared methods or confidence intervals for the reported success rates.
The evidence remains preliminary. The paper is an arXiv preprint and has not been peer reviewed; the source text provides benchmark claims from the authors, not independent replication or deployment data.
The authors also reported dual-arm transport experiments under dynamic interference, saying they showed online response and practical deployability. The supplied source text does not give a dated release, review milestone or commercial deployment plan.
Source: arXiv preprint, arXiv, Oct. 14, 2026
More stories
- Steward AI trader limits live-test loss to 0.3%
- Gemini flags 69% of held-out thermal-video falls
- Anthropic reports $80.7 billion loss ahead of planned IPO
- Electronic Arts layoffs close BioWare, cut about 400 jobs
- Türkiye Desk: Flow Games’ $49m funding line sharpens mobile focus
- Sceye tests 4G service from 54,000 feet over Japan
- Japan & Asia: Switch 2 leads Famitsu chart with 22,420 units
- Kotukh maps quantum side-channel edge to AES-128 rank 2^58.6
- AI framework excludes open models from US model reviews
- Palantir stock rally hands shorts $3 billion paper loss
Latest news
- Damages dispute puts Trump finances at center of lawsuit
- Apple Finally Folds, and the Critics Are Mostly Charmed
- Venezuela protests seek elections as vote dates stay unset
- Citi gets China securities license, now faces scale test
- Xizang earthquake blocks highway as crews build shelters
- Typhoon Champi weakens but keeps Taiwan largely shut down
- Zelensky urges Trump to press Putin into ceasefire talks
- Oil and Iran frame Trump’s pitch before November midterms